Robotics and Computer Vision Lab

Research Area

JIT
조회 수 817 추천 수 0 댓글 0
?

단축키

Prev이전 문서

Next다음 문서

가 크게 작게 위로 아래로 댓글로 가기 인쇄 첨부
?

단축키

Prev이전 문서

Next다음 문서

가 크게 작게 위로 아래로 댓글로 가기 인쇄 첨부

1879535083_4vdLfG8t_1.jpg


 Members : Jungho Kim, Seunghak Shin, Jaesik Park

 Associated center : Samsung techwin co.


Overview

1. Purpose of project.
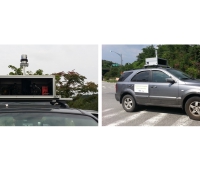
Developing self-localization technology for mobile surveillance robot.

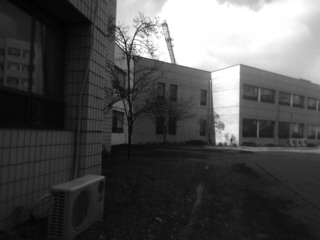
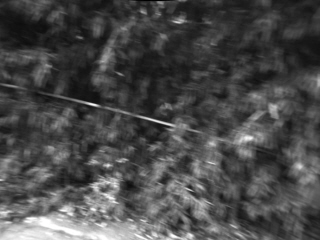
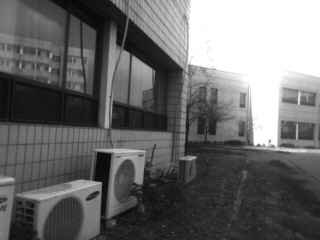
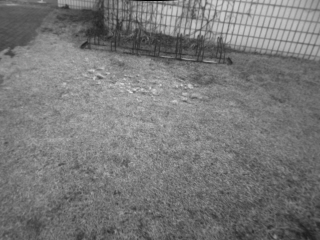
To track and follow people or objects, mobile robot should have self-localization and self-driving related algorithms. In this research, we propose a sensor-fusion based self-localization system that can be applied to intelligence robots on outside conditions. In outdoors, usually vision based localization approach suffer from many obstacles; abrupt luminance changes, ambiguous scene images and motion blur (Fig 1, 2).


dxw7gM5MR1UC1U3F.jpg   XSbPWIIHAoiS32Bqm.jpg


< Fig 1. Abrupt Illumination changes >
 

YA7psCF4sER.jpg   k5izxTyvhYyb.jpg


< Fig 2. limitations of vision based approach - ambiguous scene images and motion blur >


To solve this problem, the sensor-fusion system proposed. The system composed of LRF (Laser Range Finder), multiple cameras and DGPS (Differential Global Positioning System) can be applied to position estimation process. Therefore, even in the bad weather or night condition, the robot can estimate its location correctly.


2. Self-localization techniques.
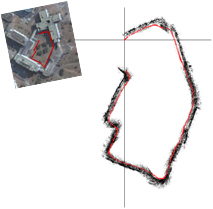
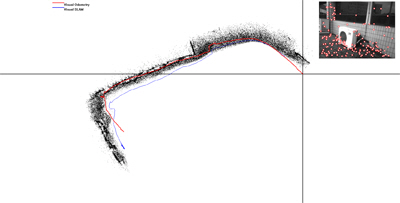
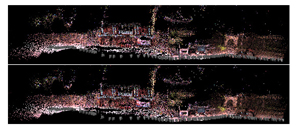
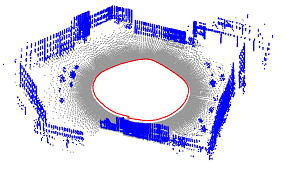
We have been developed several techniques to achieve our goal. (Fig 3, 4, 5)
 

E7k9DwThtruAlSNKMf4kSY1sAHGI6.jpg

< Fig 3. Stereo camera based real-time localization technique >
 

Sk14OvCiHl6bsKlweFW.jpg


< Fig 4. Single camera based localization algorithm >
 

sVqKNKdsACPNdJwvn3rI.jpg

< Fig 5. Camera-Laser fusion system for estimating location >


3. Sensor fusion system.
If local information is gathered by camera or laser sensors, the error can be accumulated because these sensors do not have global perspective. The sensor-fusion algorithm can solve this problem. To be specific, using the local sensors such as camera or laser, we can estimate mobile robot’s motion and direction. Additionally, the global sensors, DGPS can gather accurate location information. Therefore, overall performance can be improved when we use those data alternatively.


  1. No Image

    Pixel-level Video Recognition and Understanding Projects

    Date2024.03.11 CategoryProject Views412
    Read More
  2. MTMMC: A Large-Scale Real-World Multi-Modal Camera Tracking Benchmark

    Date2024.03.11 CategoryProject Views523
    Read More
  3. [2021 Research Area] 1. Recognition

    Date2021.05.28 CategoryReasearch Area Views2071
    Read More
  4. [2021 Research Area] 2. Video and Language

    Date2021.05.28 CategoryReasearch Area Views821
    Read More
  5. [2021 Research Area] 3. Video Processing

    Date2021.05.28 CategoryReasearch Area Views805
    Read More
  6. [2021 Research Area] 4. Domain Adaptation

    Date2021.05.28 CategoryReasearch Area Views804
    Read More
  7. [2021 Research Area] 5. 3D and Depth Completion

    Date2021.05.28 CategoryReasearch Area Views1674
    Read More
  8. [2021 Research Area] 6. Adversarial Attack

    Date2021.05.28 CategoryReasearch Area Views30324
    Read More
  9. [2021 Research Area] 7. Multi-Modal Learning

    Date2021.05.28 CategoryReasearch Area Views1761
    Read More
  10. [2021 Research Area] 8. Machine Learning

    Date2021.05.28 CategoryReasearch Area Views602
    Read More
  11. [2021 Research Area] 9. Semi Supervised Learning

    Date2021.05.28 CategoryReasearch Area Views525
    Read More
  12. [2021 Research Area] 10. Sign Language

    Date2021.05.28 CategoryReasearch Area Views540
    Read More
  13. [2021 Research Area] 11. Vehicle and Robot

    Date2021.05.28 CategoryReasearch Area Views1104
    Read More
  14. Visual Perception for Autonomous Driving in Day and Night

    Date2018.02.27 CategoryProject Views1383
    Read More
  15. Megacity Modeling

    Date2018.02.27 CategoryProject Views1076
    Read More
  16. Intelligent Robot Vision System Research Center (Localization technology development Team)

    Date2018.02.27 CategoryProject Views817
    Read More
  17. i3D: Interactive Full 3D Service (Foreground/Background Segmentation Part)

    Date2018.02.27 CategoryProject Views844
    Read More
  18. National Research Lab: Development of Robust Vision Technology for Object Recognition and Shape Modeling of Intelligent Robot

    Date2018.02.27 CategoryProject Views880
    Read More
  19. Intelligent Robot Vision System Research Center (Detection Tracking Research Team)

    Date2018.02.27 CategoryProject Views1057
    Read More
  20. [2018] RCV lab Research Fields

    Date2018.02.27 CategoryReasearch Area Views4222
    Read More
Board Pagination Prev 1 2 Next
/ 2