Robotics and Computer Vision Lab

Research Area

JIT
조회 수 1057 추천 수 0 댓글 0
?

단축키

Prev이전 문서

Next다음 문서

가 크게 작게 위로 아래로 댓글로 가기 인쇄 첨부
?

단축키

Prev이전 문서

Next다음 문서

가 크게 작게 위로 아래로 댓글로 가기 인쇄 첨부

1879535079_PUyi6K0a_main_.jpg


 Members : Rockhun Do, JoonYoung Lee, Eunji Song.

 Associated center : Samsung Techwin


Overview

Developing Detection and Tracking Algorithm Working on a Mobile Robot.


Our goal is to develop algorithms that we can apply on mobile robots, but currently we focus on algorithms for static camera in order to form our fundamental structure.


Detection

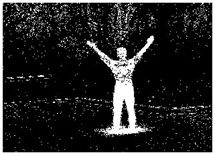
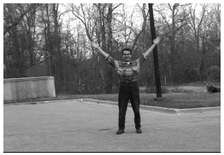
When detecting object, we need to consider noises due to environmental changes, illumination changes, and many other causes.


vpaOgMO2TrC4VOKnxXZ4LgxE.jpgb1xx1LRTZ.jpg

Detection in dynamic environment


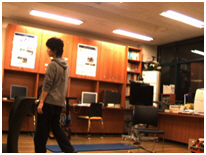
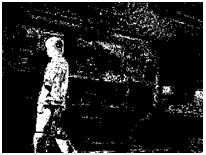
lehCSKUSNexpWYI6W3lz1xcEEKFATx.jpgljlSazsGd16msDc2v2qCB1e3W5.jpg

Detection when there is illumination change

 Current techniques for background subtraction have limitations as you can see from the images above. There are many false alarms caused by noises such as tree waving, color similarities between background and foreground, etc. Besides, pixel intensities change through the whole area when illumination changes and it is hard to decide if the change is from the light or from the foreground movement. To solve such problems, we are trying to model noises precisely so that we can correctly figure out where those false alarms coming from. Moreover, we are developing detection algorithm which is also robust to weather conditions like rain, snow, or wind.
 

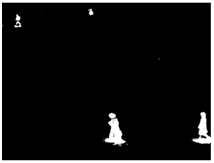
csxaP7zo4Z4jKNPjfxwA764NOxzmIu8R.jpgXgtDdIgVXxbnruyEQAlc4MpgxiQmlX.jpg

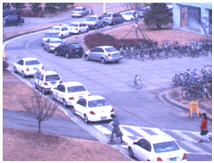
Detecting the objects at a long distance


In addition to that, we are also considering about objects at a long distance.


Tracking


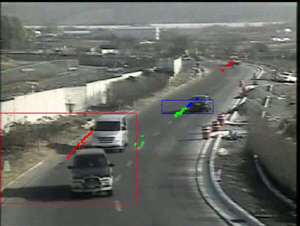
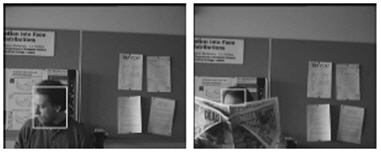
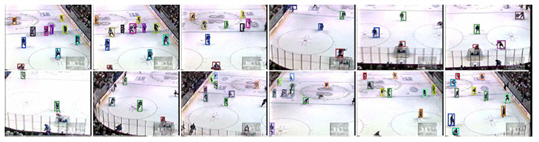
Tracking algorithm need to track objects even if the object is blocked or is intersecting with another object. Although cameras would be static in current stage, we are developing algorithm that is applicable when the camera unit can do panning and tilting so that we can control the camera to make the object located at the center of the image.
 

dOMhnG65.jpg

Object tracking when there is an occlusion.
 

padnQU6vwDNWP66WH7ZiBdnOLSJ.jpg

Tracking many objects when there are intersections among the objects.


In order to succeed the tracking algorithm in such environment and limitations, we need to use not only color or texture information but also motion models of the objects. Moreover, we need to extract features from the objects and store them. Thus, we can robustly estimate where the object would be using the motion model and we can also verify and adjust the results using the specific descriptions.


  1. No Image

    Pixel-level Video Recognition and Understanding Projects

    Date2024.03.11 CategoryProject Views412
    Read More
  2. MTMMC: A Large-Scale Real-World Multi-Modal Camera Tracking Benchmark

    Date2024.03.11 CategoryProject Views523
    Read More
  3. [2021 Research Area] 1. Recognition

    Date2021.05.28 CategoryReasearch Area Views2071
    Read More
  4. [2021 Research Area] 2. Video and Language

    Date2021.05.28 CategoryReasearch Area Views821
    Read More
  5. [2021 Research Area] 3. Video Processing

    Date2021.05.28 CategoryReasearch Area Views805
    Read More
  6. [2021 Research Area] 4. Domain Adaptation

    Date2021.05.28 CategoryReasearch Area Views804
    Read More
  7. [2021 Research Area] 5. 3D and Depth Completion

    Date2021.05.28 CategoryReasearch Area Views1674
    Read More
  8. [2021 Research Area] 6. Adversarial Attack

    Date2021.05.28 CategoryReasearch Area Views30324
    Read More
  9. [2021 Research Area] 7. Multi-Modal Learning

    Date2021.05.28 CategoryReasearch Area Views1761
    Read More
  10. [2021 Research Area] 8. Machine Learning

    Date2021.05.28 CategoryReasearch Area Views602
    Read More
  11. [2021 Research Area] 9. Semi Supervised Learning

    Date2021.05.28 CategoryReasearch Area Views525
    Read More
  12. [2021 Research Area] 10. Sign Language

    Date2021.05.28 CategoryReasearch Area Views540
    Read More
  13. [2021 Research Area] 11. Vehicle and Robot

    Date2021.05.28 CategoryReasearch Area Views1104
    Read More
  14. Visual Perception for Autonomous Driving in Day and Night

    Date2018.02.27 CategoryProject Views1383
    Read More
  15. Megacity Modeling

    Date2018.02.27 CategoryProject Views1076
    Read More
  16. Intelligent Robot Vision System Research Center (Localization technology development Team)

    Date2018.02.27 CategoryProject Views817
    Read More
  17. i3D: Interactive Full 3D Service (Foreground/Background Segmentation Part)

    Date2018.02.27 CategoryProject Views844
    Read More
  18. National Research Lab: Development of Robust Vision Technology for Object Recognition and Shape Modeling of Intelligent Robot

    Date2018.02.27 CategoryProject Views880
    Read More
  19. Intelligent Robot Vision System Research Center (Detection Tracking Research Team)

    Date2018.02.27 CategoryProject Views1057
    Read More
  20. [2018] RCV lab Research Fields

    Date2018.02.27 CategoryReasearch Area Views4222
    Read More
Board Pagination Prev 1 2 Next
/ 2